Jiaxi Jiang 蒋佳熹
Postdoctoral Researcher
ETH Zurich, Switzerland
CV | Google Scholar | Github | LinkedIn | X (Twitter) | Email
About Me
I am a Postdoctoral Researcher in Humanoid Robot Learning at the Mobile Robotics Lab, ETH Zurich, working with Prof. Stefan Leutenegger. I did my PhD in Computer Science at ETH Zurich with Prof. Christian Holz at the Sensing, Interaction & Perception Lab. During my PhD, I was also a Research Scientist Intern at Meta Reality Labs Research with Dr. Federica Bogo.
I received my MSc in Computational Engineering Science from RWTH Aachen University, writing my thesis at the Computer Vision Lab, ETH Zurich, with Prof. Kai Zhang and Prof. Radu Timofte. I also did a research visit on robot teleoperation with Dr. Shuang Li and Prof. Jianwei Zhang at the University of Hamburg, and worked at the Max Planck Institute for Intelligent Systems and the Max Planck Institute for Informatics.
Research
My research connects humanoid robot learning with human motion modeling. My work has focused on scalable human motion capture in the wild through egocentric and wearable sensing, and on transferring captured human motion to agents that move and interact naturally with people, both as virtual characters in mixed reality and as humanoid robots in the physical world. Specifically, I am interested in:
- Humanoid Robot Learning: Learning humanoid perception and whole-body skills from human motion and video, toward natural interaction between people and humanoid robots.
- Human Motion Modeling: Foundation and world models that reconstruct, predict, and generate human motion and interaction, with applications in AR/VR, animation, robotics, and healthcare.
- Egocentric Perception: Scalable capture and understanding of full-body human activity and human–scene interaction from egocentric and wearable sensing.
News
- 11/2026 I join the Mobile Robotics Lab at ETH Zurich as a Postdoctoral Researcher.
- 10/2026 Our new preprint HumanoidPose is out on arXiv.
- 07/2026 I am selected for the Doctoral Consortium at ECCV 2026.
- 06/2026 Our paper EgoExoMoCap is accepted by ECCV 2026 as an Oral presentation. See you in Malmö, Sweden!
- 06/2025 I join Meta Zurich as a Research Scientist Intern.
- 06/2025 Our paper Group Inertial Poser is accepted by ICCV 2025. See you in Hawaii!
- 05/2025 Our paper Garment Inertial Poser is accepted by IJCAI 2025.
- 09/2024 Our paper EgoSim is accepted by NeurIPS 2024.
- 07/2024 Two papers EgoPoser and MANIKIN are accepted by ECCV 2024. See you in Milan!
- 04/2024 Our paper Ultra Inertial Poser is accepted by SIGGRAPH 2024.
- 08/2023 Our paper TapLight is accepted by UIST 2023.
- 09/2022 I am awarded the Springorium Commemorative Coin during the graduation ceremony by RWTH Aachen.
- 07/2022 Our paper AvatarPoser is accpeted by ECCV 2022.
- 02/2022 Our paper TapType is accepted by CHI 2022.
- 07/2021 I join Sensing, Interaction & Perception Lab, ETH Zurich as a research assistant.
- 07/2021 My master's thesis FBCNN is accepted by ICCV 2021! Great appreciation to Dr. Kai Zhang and Prof. Radu Timofte!
- 04/2021 I get my master's degree with distinction from RWTH Aachen University.
- 09/2020 I start my master's thesis at the Computer Vision Lab, ETH Zurich as an IDEA League research student.
- 06/2020 Our paper on Teleoperation is accepted by IROS 2020.
Publications (* co-supervised projects)
-
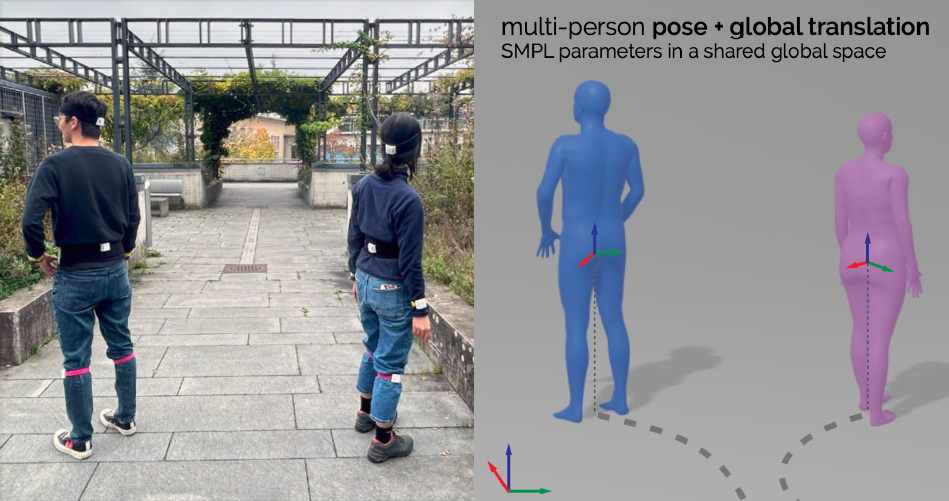
Group Inertial Poser: Multi-Person Pose and Global Translation from Sparse Inertial Sensors and Ultra-Wideband Ranging International Conference on Computer Vision (ICCV), 2025. Project Page Paper Poster BibTeX Dataset Code Multi-person mocap from sparse IMUs was thought infeasible. Ultra-wideband ranging between wearers makes it work — anywhere, with no cameras.
@inproceedings{xue2025groupinertialposer, title={Group Inertial Poser: Multi-Person Pose and Global Translation from Sparse Inertial Sensors and Ultra-Wideband Ranging}, author={Xue, Ying and Jiang, Jiaxi and Armani, Rayan and Hollidt, Dominik and Liao, Yi-Chi and Holz, Christian}, booktitle={Proceedings of the IEEE/CVF International Conference on Computer Vision (ICCV)}, pages={24910--24921}, year={2025} } -
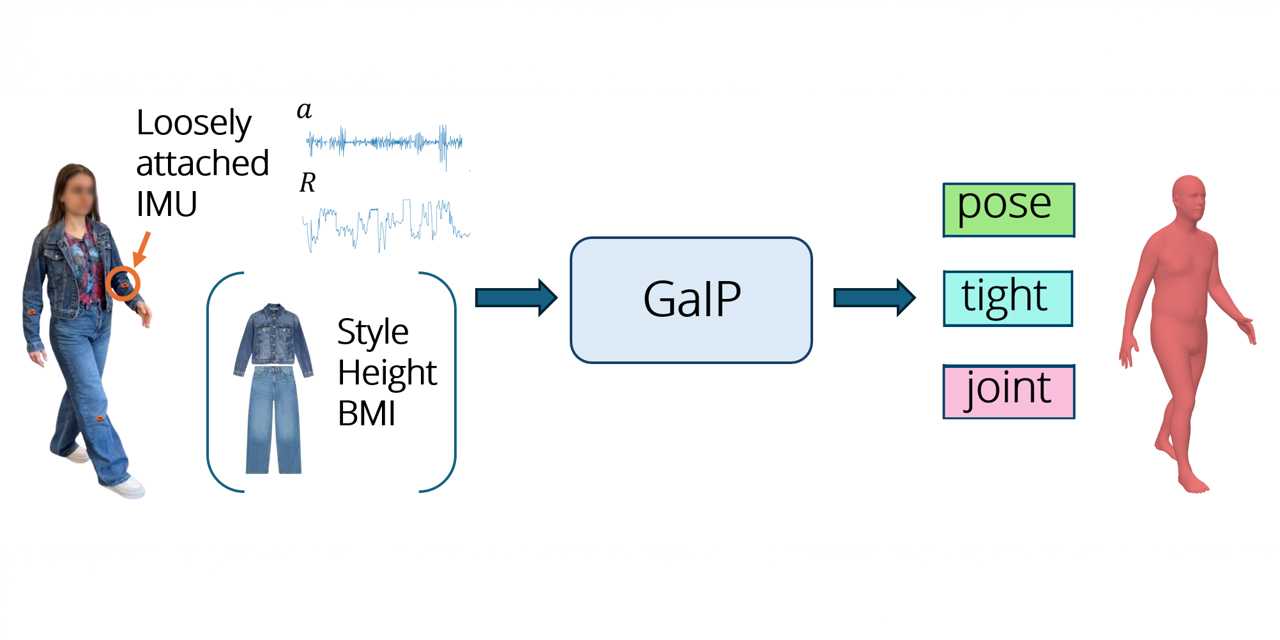
Garment Inertial Poser: Human Motion Capture from Loose and Sparse Inertial Sensors with Garment-aware Diffusion Models International Joint Conferences on Artificial Intelligence (IJCAI), 2025. Project Page Paper BibTeX Mocap escapes the lab and moves into real clothing: a diffusion model that knows how IMUs slide and swing with loose fabric.
@article{ilic2025human, title={Human Motion Capture from Loose and Sparse Inertial Sensors with Garment-aware Diffusion Models}, author={Ilic, Andela and Jiang, Jiaxi and Streli, Paul and Liu, Xintong and Holz, Christian}, journal={arXiv preprint arXiv:2506.15290}, year={2025} } -
EgoSim: An Egocentric Multi-view Simulator and Real Dataset for Body-worn Cameras during Motion and Activity Neural Information Processing Systems (NeurIPS), 2024 Project Page Paper Video BibTeX Dataset Code A simulator and paired real-world dataset that finally expose egocentric vision to the blur, occlusion, and swing body-worn cameras actually endure.
@inproceedings{hollidtegosim, title={EgoSim: An Egocentric Multi-view Simulator and Real Dataset for Body-worn Cameras during Motion and Activity}, author={Hollidt, Dominik and Streli, Paul and Jiang, Jiaxi and Haghighi, Yasaman and Qian, Changlin and Liu, Xintong and Holz, Christian}, booktitle={The Thirty-eight Conference on Neural Information Processing Systems Datasets and Benchmarks Track} } -
Ultra Inertial Poser: Scalable Motion Capture and Tracking from Sparse Inertial Sensors and Ultra-Wideband Ranging ACM SIGGRAPH 2024 Project Page Paper Video BibTeX Code Global drift has haunted sparse-IMU mocap for years. Ultra-wideband ranging between sensors anchors absolute position and limb geometry — camera-free, marker-free.
@article{armani2024ultra, title={Ultra Inertial Poser: Scalable Motion Capture and Tracking from Sparse Inertial Sensors and Ultra-Wideband Ranging}, author={Armani, Rayan and Qian, Changlin and Jiang, Jiaxi and Holz, Christian}, journal={arXiv preprint arXiv:2404.19541}, year={2024} } -
Structured Light Speckle: Joint Ego-Centric Depth Estimation and Low-Latency Contact Detection via Remote Vibrometry ACM Symposium on User Interface Software and Technology (UIST), 2023. Project Page Paper Video Talk BibTeX A single camera reads dense depth and low-latency touch off any surface — by decoding the faint tremor of laser speckle.
@inproceedings{uist2023-structured_light_speckle, author = {Streli, Paul and Jiang, Jiaxi and Rossie, Juliete and Holz, Christian}, title = {Structured Light Speckle: Joint Ego-Centric Depth Estimation and Low-Latency Contact Detection via Remote Vibrometry}, year = {2023}, isbn = {9798400701320}, publisher = {Association for Computing Machinery}, address = {New York, NY, USA}, doi = {https://doi.org/10.1145/3586183.3606749}, booktitle = {Proceedings of the 36th Annual ACM Symposium on User Interface Software and Technology}, articleno = {26}, numpages = {12} } -
TapType: Ten-Finger Text Entry on Everyday Surfaces via Bayesian Inference ACM CHI Conference on Human Factors in Computing Systems (CHI), 2022. Project Page Paper Video Demo BibTeX Ten-finger typing on any flat surface — a table, a desk, a wall — wearing nothing but two wristbands.
@inproceedings{chi2022-taptype, author = {Streli, Paul and Jiang, Jiaxi and Fender, Andreas and Meier, Manuel and Romat, Hugo and Holz, Christian}, title = {TapType: Ten-finger text entry on everyday surfaces via Bayesian inference}, year = {2022}, isbn = {9781450391573}, publisher = {Association for Computing Machinery}, address = {New York, NY, USA}, doi = {https://doi.org/10.1145/3491102.3501878}, booktitle = {Proceedings of the 2022 CHI Conference on Human Factors in Computing Systems}, numpages = {16} } -
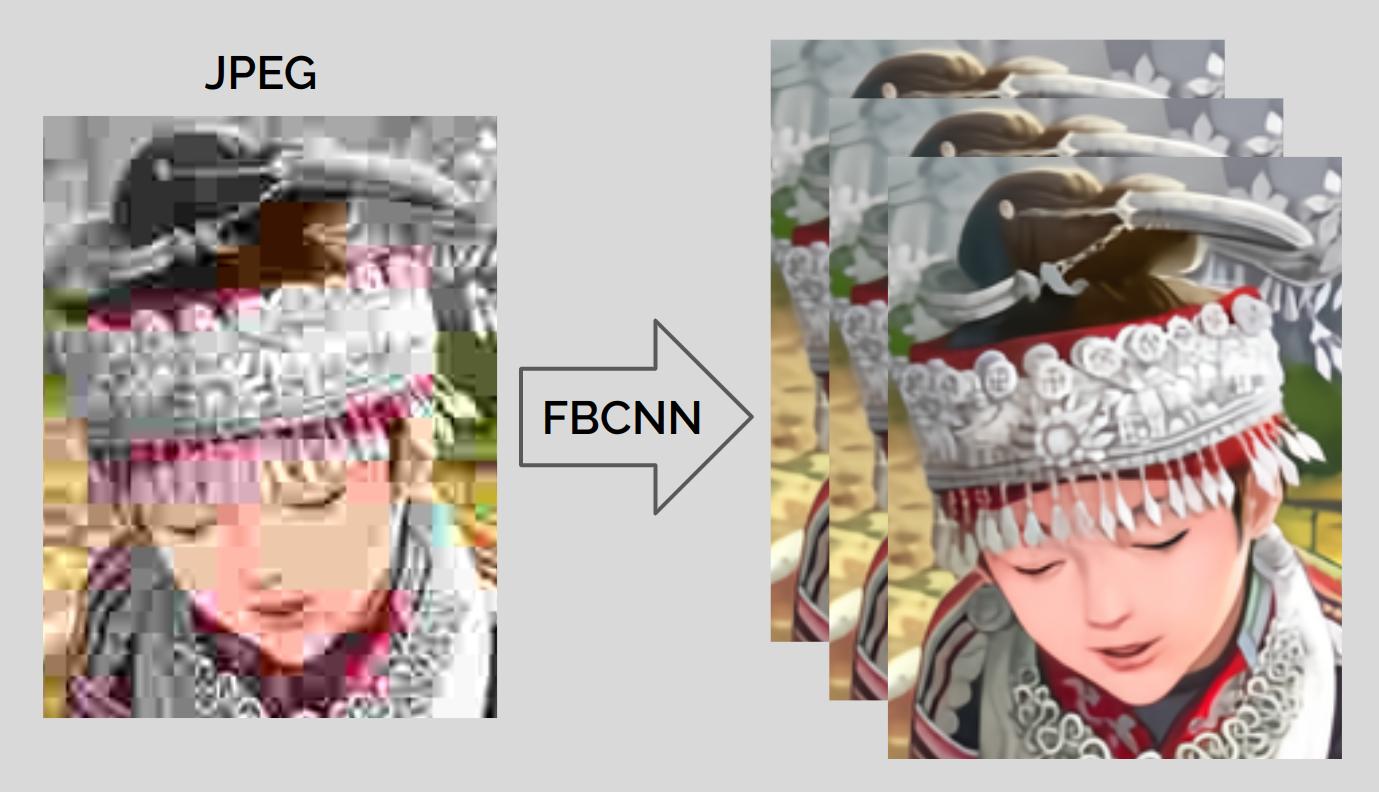
Towards Flexible Blind JPEG Artifacts Removal International Conference on Computer Vision (ICCV), 2021. Paper Poster BibTeX Code Master Thesis Blind JPEG artifact removal with a dial: trade detail against smoothness at inference time, with no retraining and no per-quality model.
@inproceedings{jiang2021towards, title={Towards Flexible Blind JPEG Artifacts Removal}, author={Jiang, Jiaxi and Zhang, Kai and Timofte, Radu}, booktitle={Proceedings of the IEEE/CVF International Conference on Computer Vision}, pages={4997--5006}, year={2021} } -
A Mobile Robot Hand-Arm Teleoperation System by Vision and IMU International Conference on Intelligent Robots and Systems (IROS), 2020. Project Page Paper Video BibTeX Code Drive a dexterous mobile manipulator in real time with only a low-cost depth camera (hand pose) and a wearable IMU device (arm pose) — no optical mocap rig.
@inproceedings{li2020mobile,
title={A mobile robot hand-arm teleoperation system by vision and imu},
author={Li, Shuang and Jiang, Jiaxi and Ruppel, Philipp and Liang, Hongzhuo and Ma, Xiaojian and Hendrich, Norman and Sun, Fuchun and Zhang, Jianwei},
booktitle={2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
pages={10900--10906},
year={2020},
organization={IEEE}
}
Academic Services
Reviewers
Computer Vision: CVPR, ICCV, ECCV, TIP
Robotics: ICRA, IROS
Computer Graphics: SIGGRAPH, SIGGRAPH Asia, ToG
Machine Learning: NeurIPS, ICLR, ICML, AAAI
Human-Computer Interaction: CHI, UIST, IEEE VR
Teaching
Egocentric Computer Vision: Perception and Understanding from the First-Person View, ETH Zurich, Spring 2026
Artificial Intelligence for Digital Characters, ETH Zurich, Spring 2025, Spring 2026
Egocentric Perception for Human-World Understanding, ETH Zurich, Spring 2025
Computer Science I, ETH Zurich, Autumn 2024
Stochastics and Machine Learning, ETH Zurich, Spring 2024
Mixed Reality, ETH Zurich, Autumn 2023
Big Data For Engineers, ETH Zurich, Spring 2023
Supervised Students
Qi Ma, Master Thesis, MSc in CS, ETH Zurich, 11.2025 - 08.2026
Nicola Witzig, Bachelor Thesis, BSc in CS, ETH Zurich, 03.2025 - 09.2025
Liuxin Qing, Semester & Master Thesis, MSc in EE, ETH Zurich, 10.2024 - 02.2026, now Software Engineer at Neura Robotics
Shuyue Wang, Master Thesis, MSc in CS, ETH Zurich, 04.2024 - 03.2025
Chang-Jin Lee, Bachelor Thesis, BSc in CS, ETH Zurich, 04.2024 - 10.2024
Andela Ilic, Master Thesis, MSc in EE, ETH Zurich, 04.2024 - 10.2024, now PhD Student at ETH Zurich
Ying Xue, Master Thesis, Research Intern, MSc in CS, ETH Zurich, 01.2024 - 05.2025, now PhD Student at ETH Zurich
Changlin Qian, Research Intern, MSc in Robotics, ETH Zurich, 09.2023 - 07.2024, now Software Engineer at Meta
Rayan Armani, Research Assistant, MSc in Robotics, ETH Zurich, 09.2023 - 03.2024, now Software Engineer at Apple
Yasaman Haghighi, Research Intern, MSc in EE, EPFL, 07.2023 - 01.2024, now PhD Student at EPFL
Xuejing Luo, Master Thesis, MSc in Robotics, ETH Zurich, 05.2023 - 02.2024, now PhD Student at Aalto University
Xintong Liu, Master Thesis, MSc in Robotics, ETH Zurich, 03.2023 - 03.2024
Filip Stanisic, Semester Thesis, MSc in EE, ETH Zurich, 03.2023 - 07.2023
Huajian Qiu, Master Thesis, MSc in CSE, EPFL, 10.2021 - 01.2022, now PhD Student at University of Stuttgart